Perrybotics 2024: Over Under
Led the mechanical design of a low-profile VEX robot, fitting the drivetrain, intake, launcher, and roughly 50 components into an 18 × 18 × 6-inch package.
What the robot needed to do
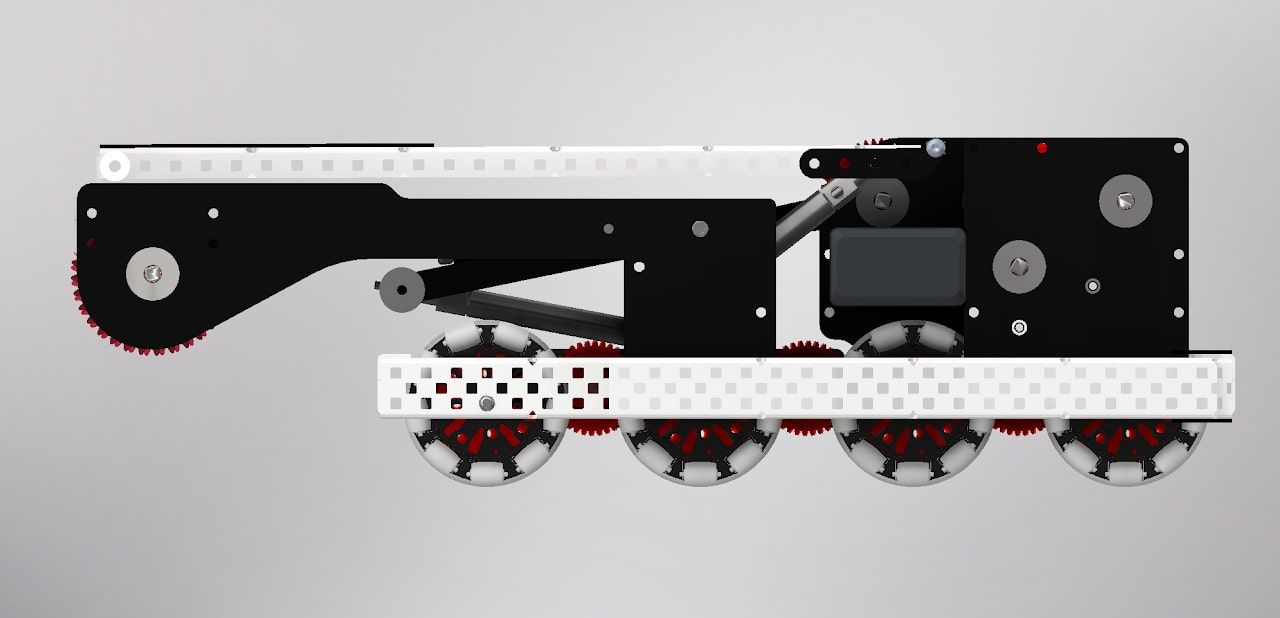
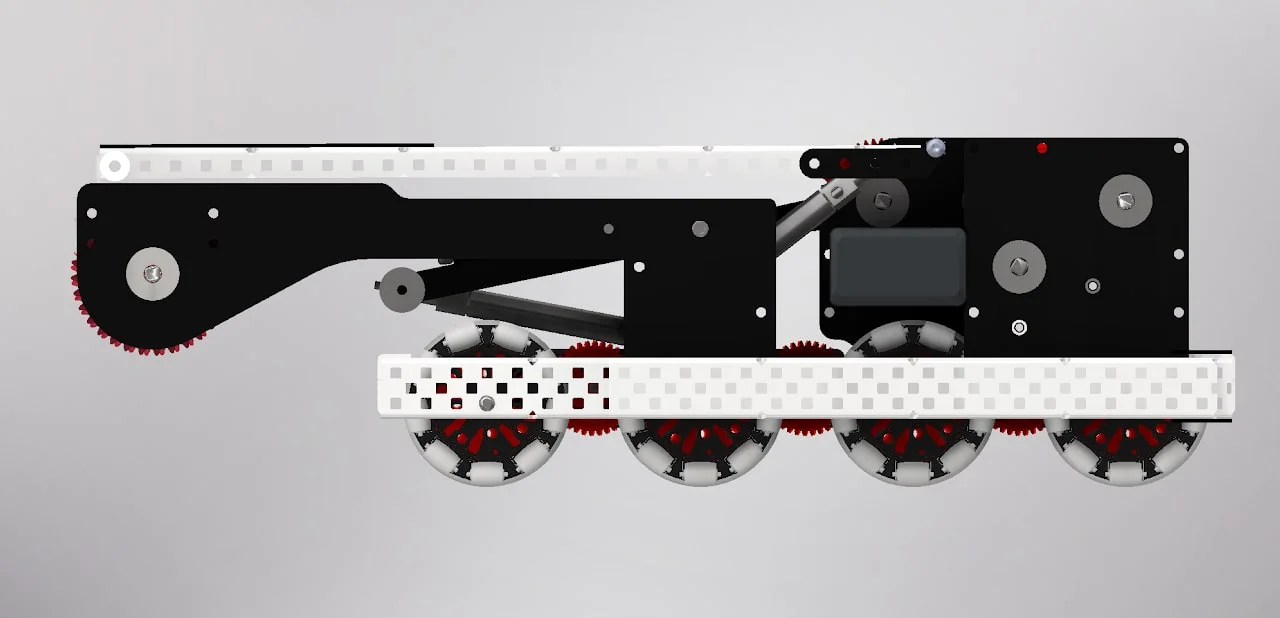
Over Under needed a robot that could drive over obstacles, pick up triballs, and launch them. We also wanted it to collapse into a low profile. I led the mechanical design and fabrication of the chassis, intake, and catapult with the team.
Chassis and drivetrain
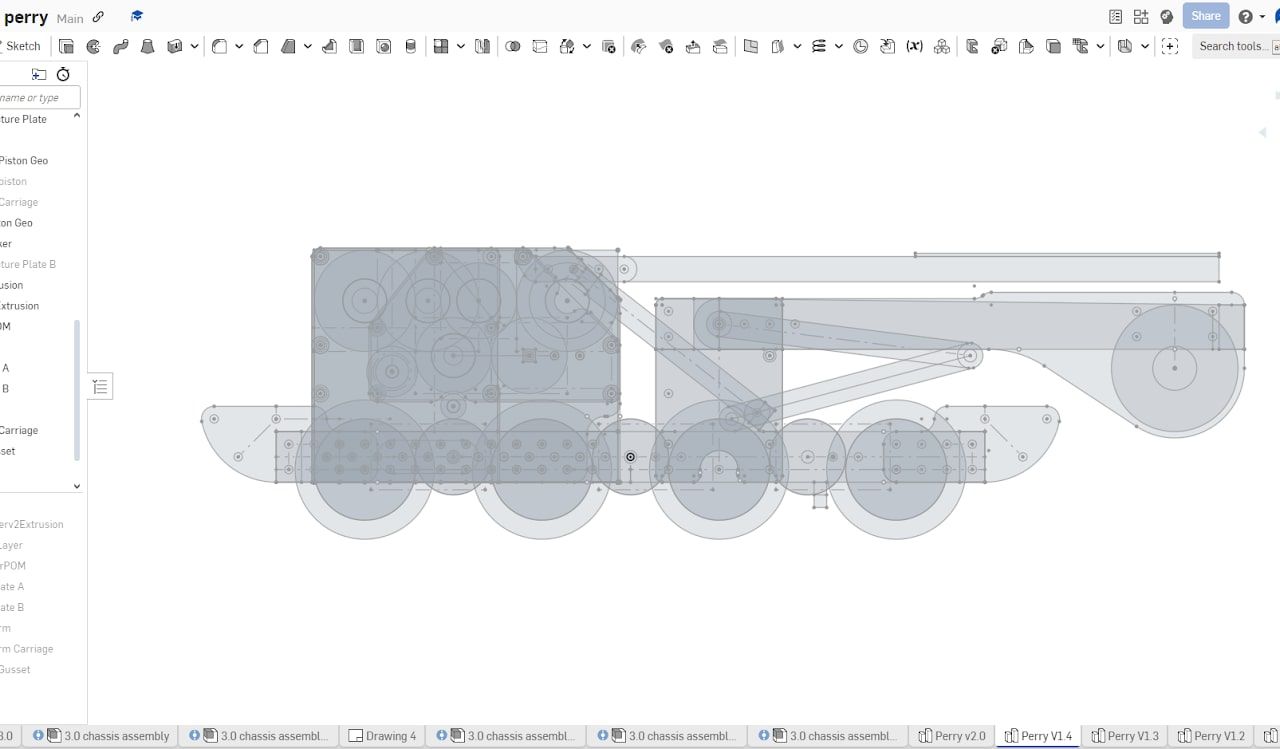
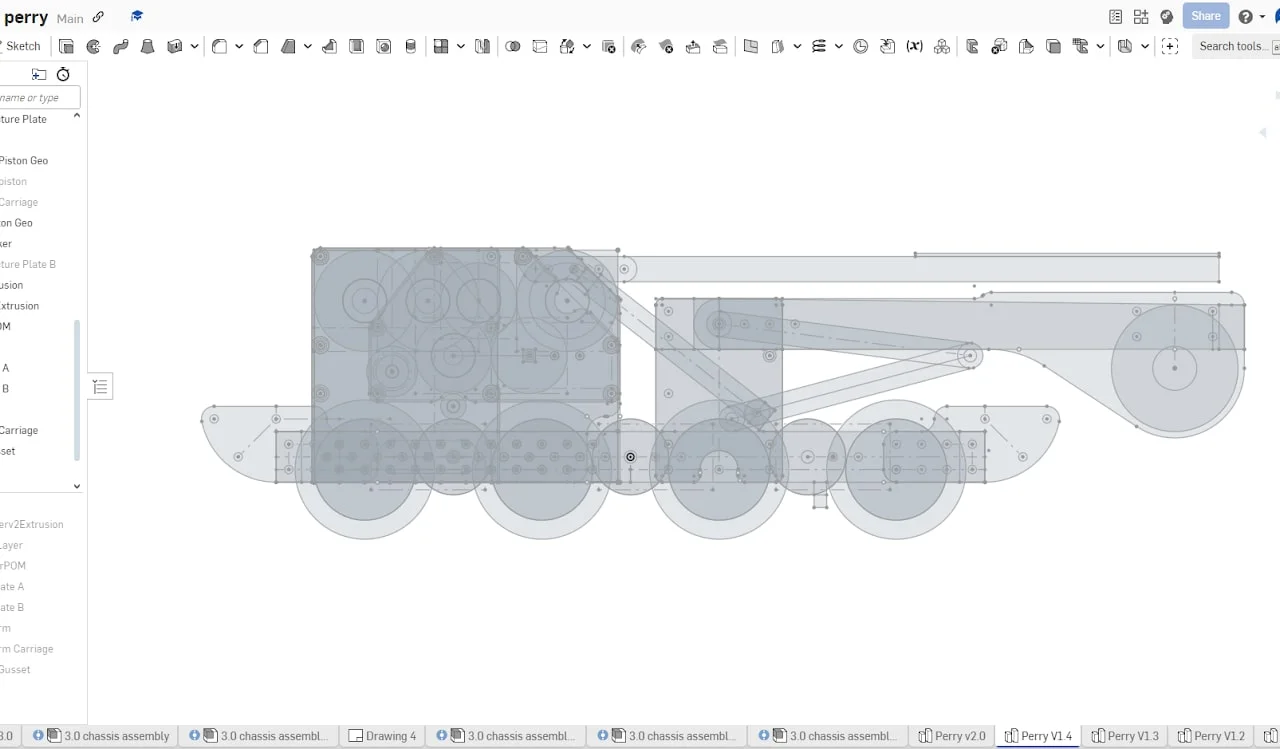
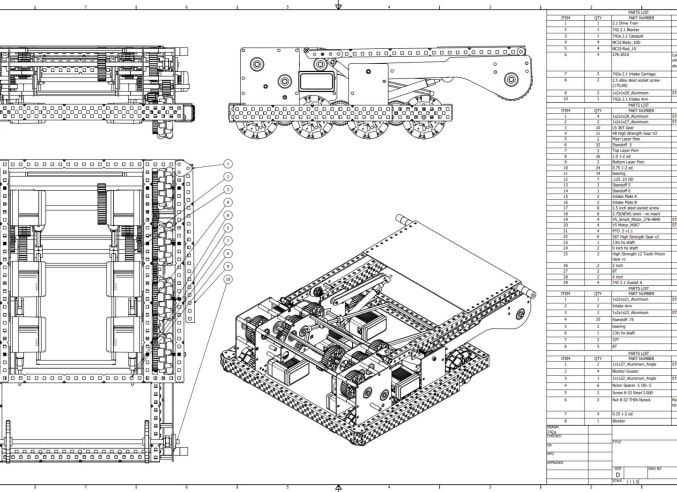
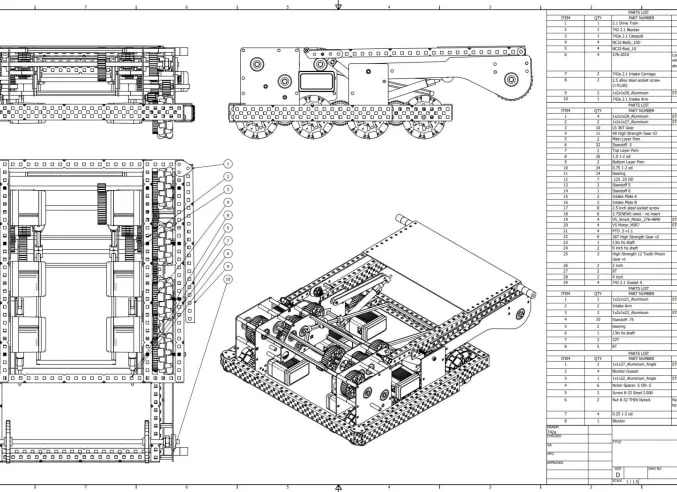
I started with master sketches in Onshape so I could place the motors and mechanisms before committing to the frame. The eight-wheel drivetrain used traction wheels inside and omni-wheels at the corners. The chassis carried the mechanism loads back into the main aluminum structure.
Intake and catapult
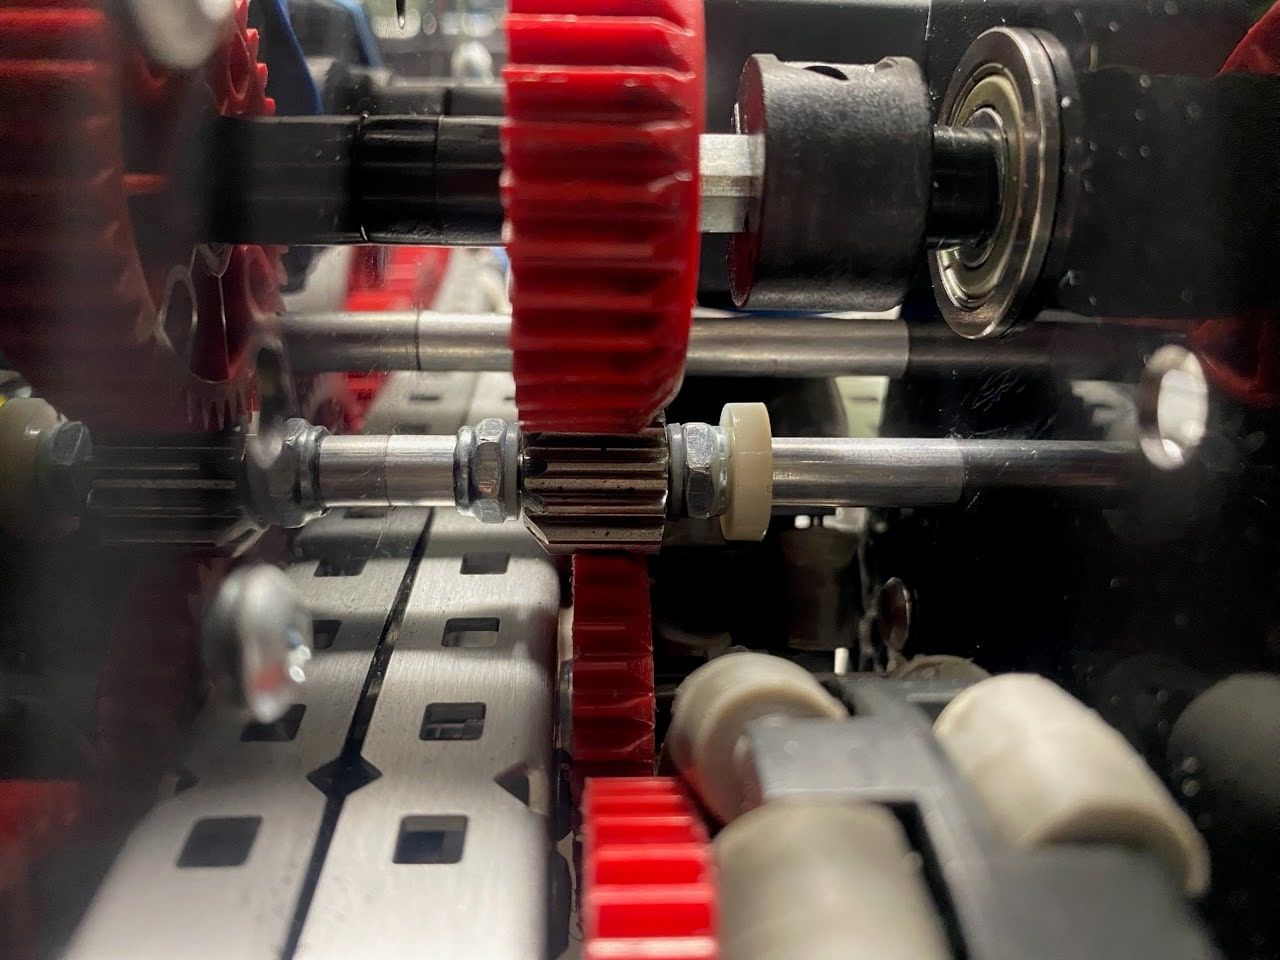
The pneumatic intake arm guided triballs into the catapult. I routed the roller-drive chain along the pitch axis so it would stay coordinated as the arm moved, then added POM guarding to reduce entanglement.
The catapult used a slip mechanism and an adjustable wire hard stop. Deployable wings helped control game pieces. Getting these systems to share the same frame was the main packaging problem.
From a quick prototype to the final parts
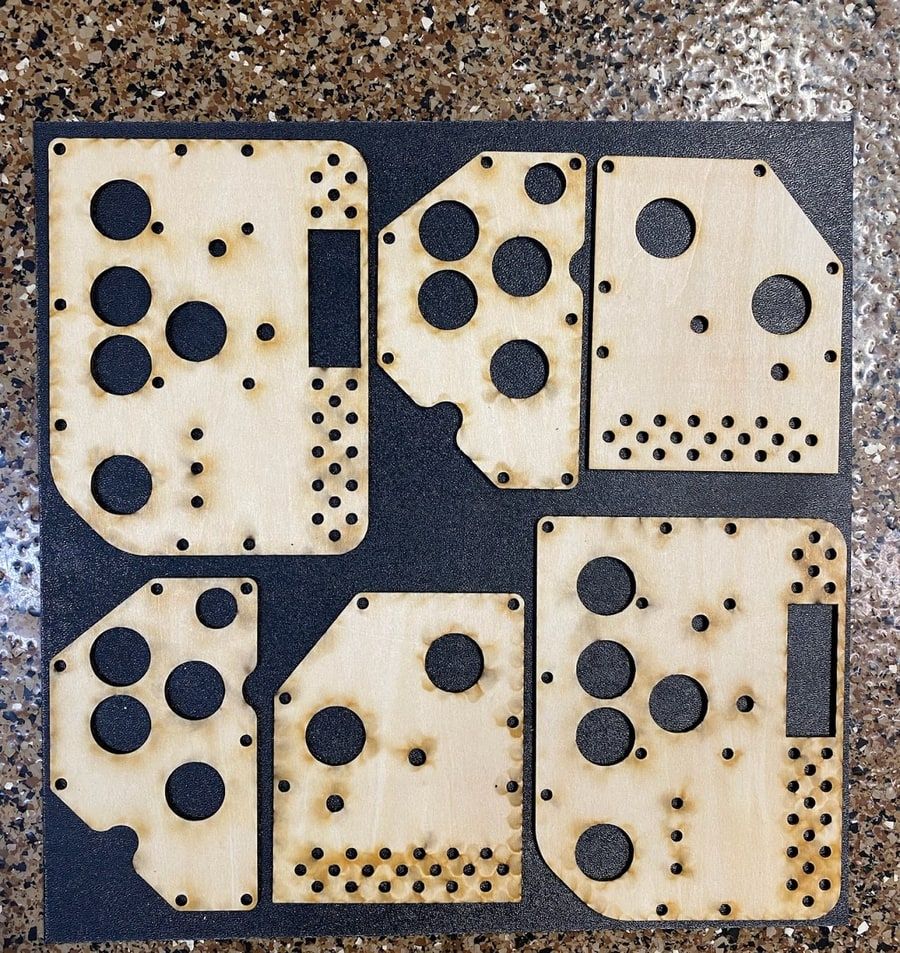
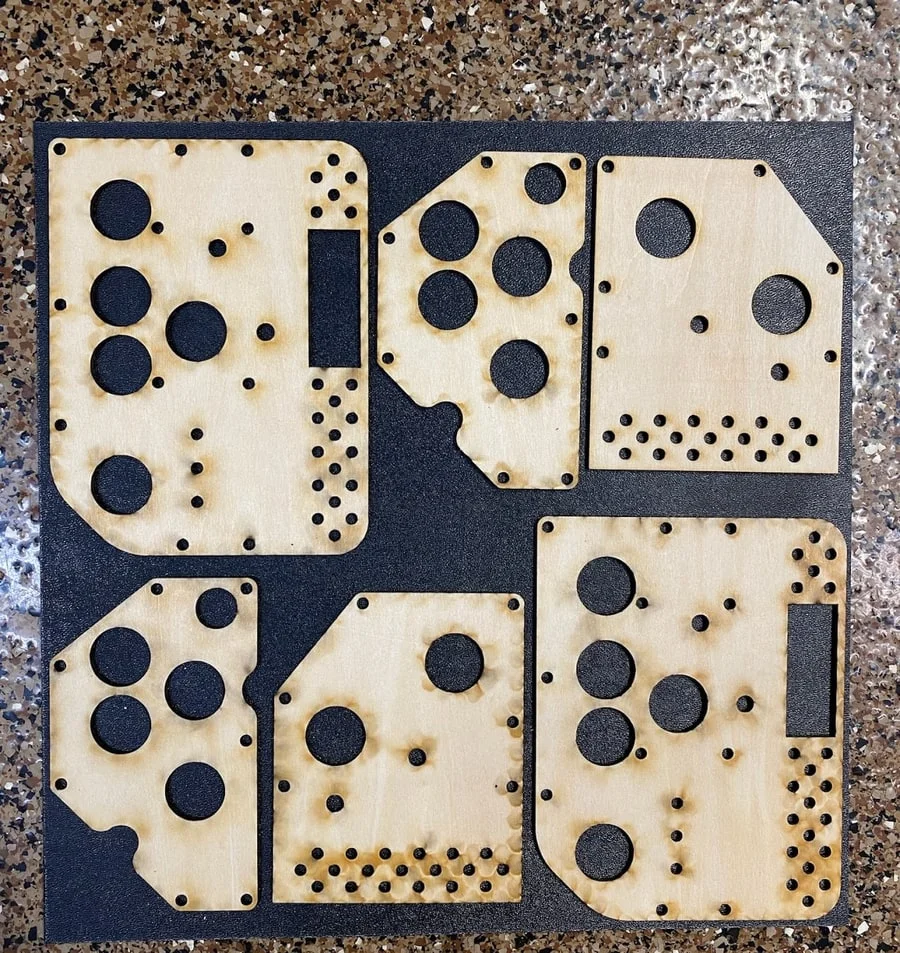
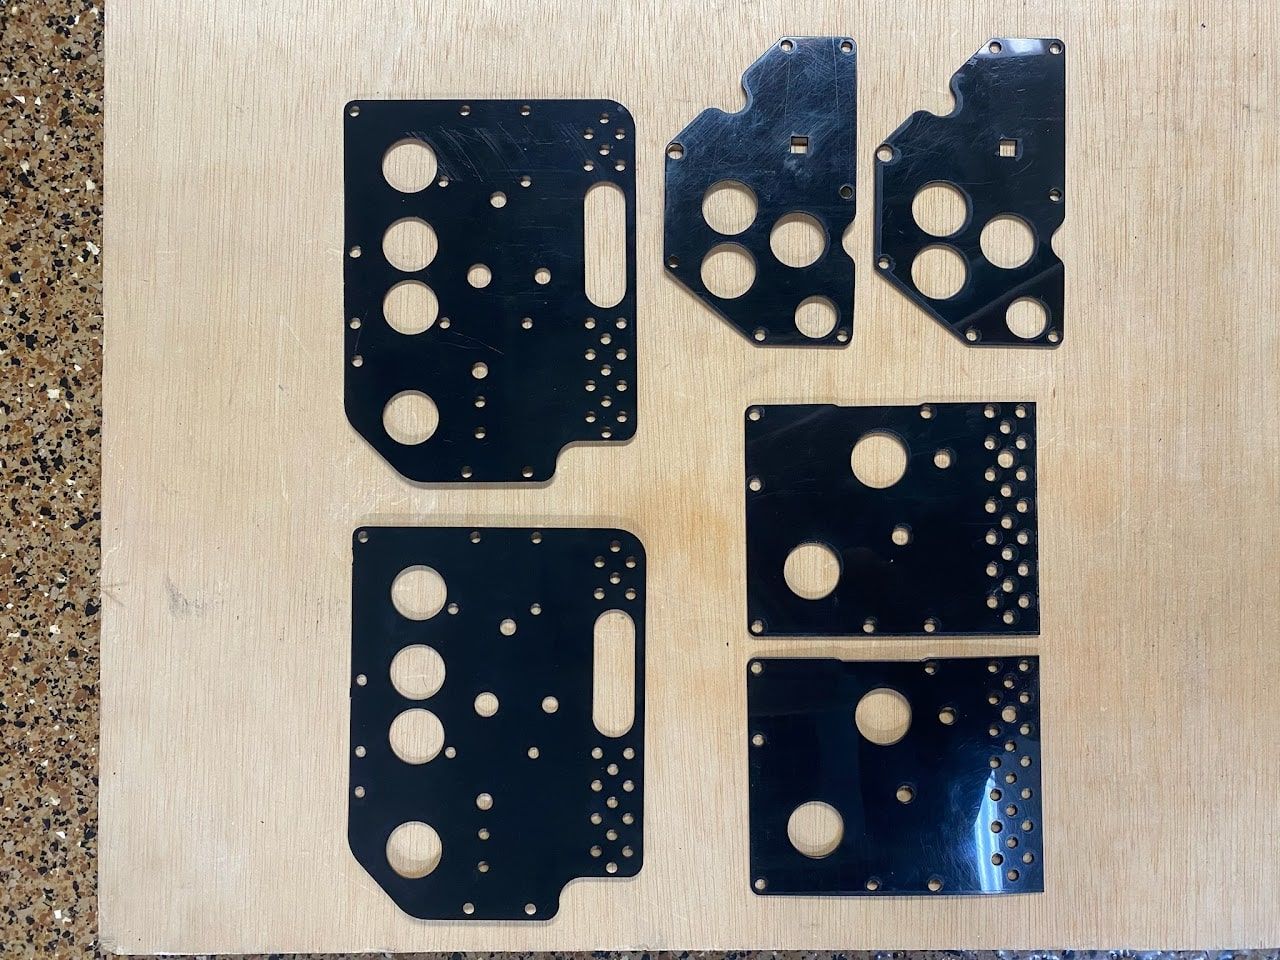
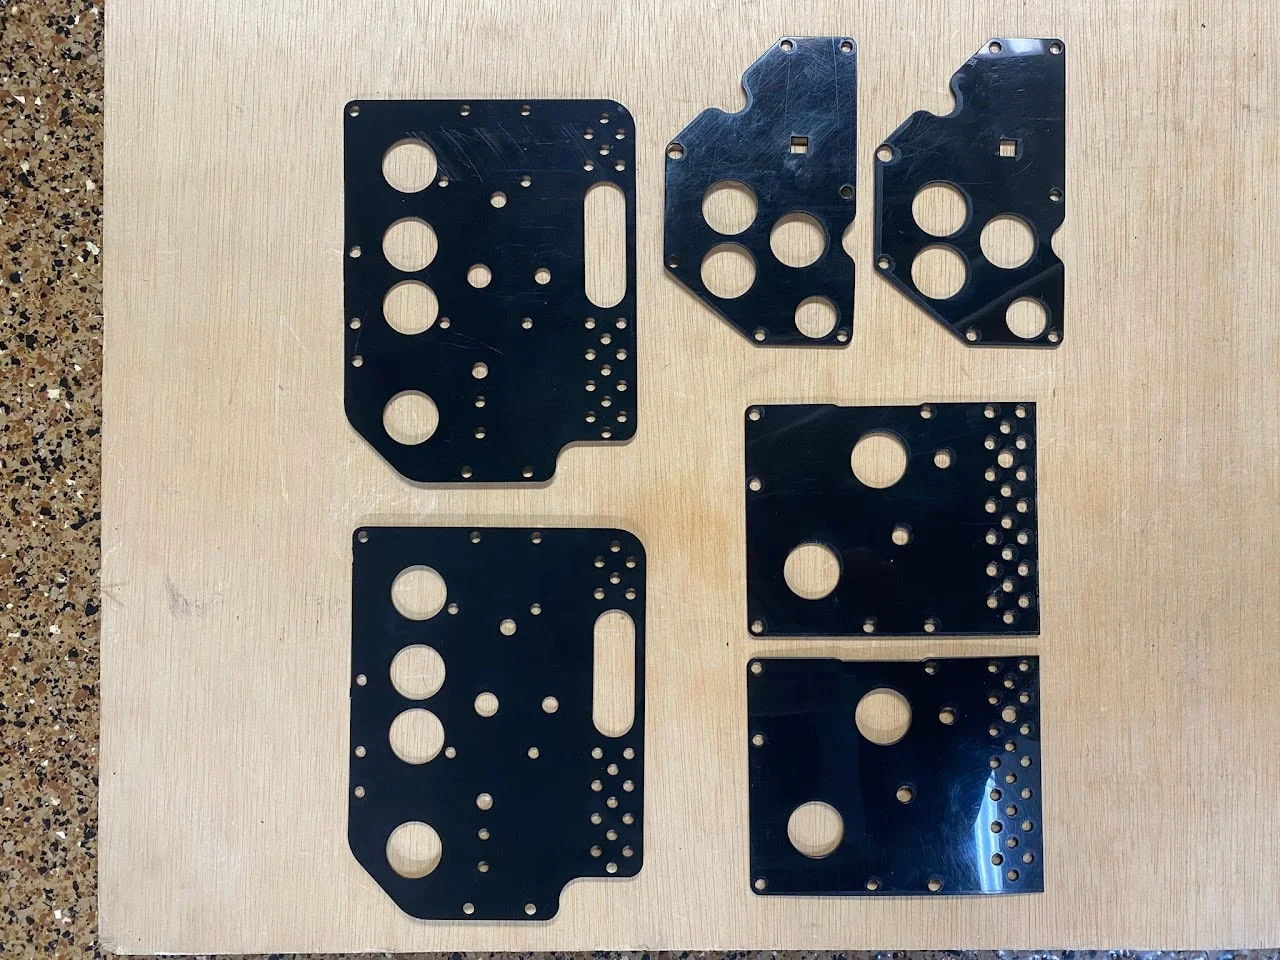
I used laser-cut balsa to check the layout before making the final plates. The build combined laser cutting, CNC routing, manual machining, and hand assembly. CAD kept the interfaces consistent as the team worked on different parts.
The gallery shows the master sketch, prototype plates, finished parts, and mechanism layout.
Result
We fit roughly 50 components into an 18 × 18 × 6-inch configuration, with a drivetrain speed of 7 ft/s.
A closer look
CAD, build photos, and technical details. Open any image for a closer look.
What I learned
Make the risky parts tangible early. A quick prototype is a lot cheaper than machining a part and finding out it blocks the intake.
Project context
The dimensions describe the low-profile configuration. Speed and component count come from the project record; the robot was built with the Perrybotics team.
Mechanical engineering, robotics, software, and applied AI internships