Perrybotics 2025: High Stakes
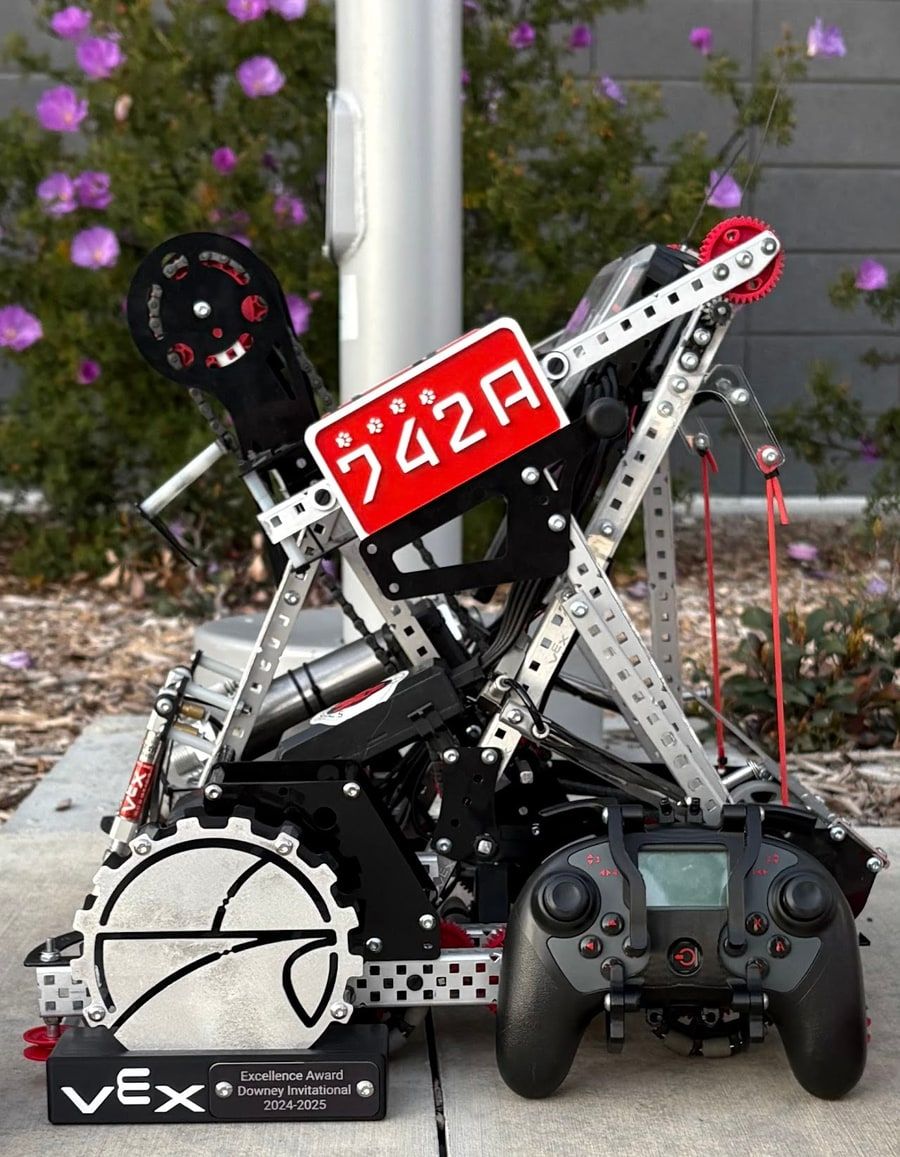
Led mechanical design and fabrication of a compact VEX robot, refining the drivetrain and mechanisms through three major iterations and removing 1.5 lb from the build.
Competition robots, independent builds, and software for engineering teams.
Each case study covers what I built, the decisions I made, and what I learned along the way.
Led mechanical design and fabrication of a compact VEX robot, refining the drivetrain and mechanisms through three major iterations and removing 1.5 lb from the build.
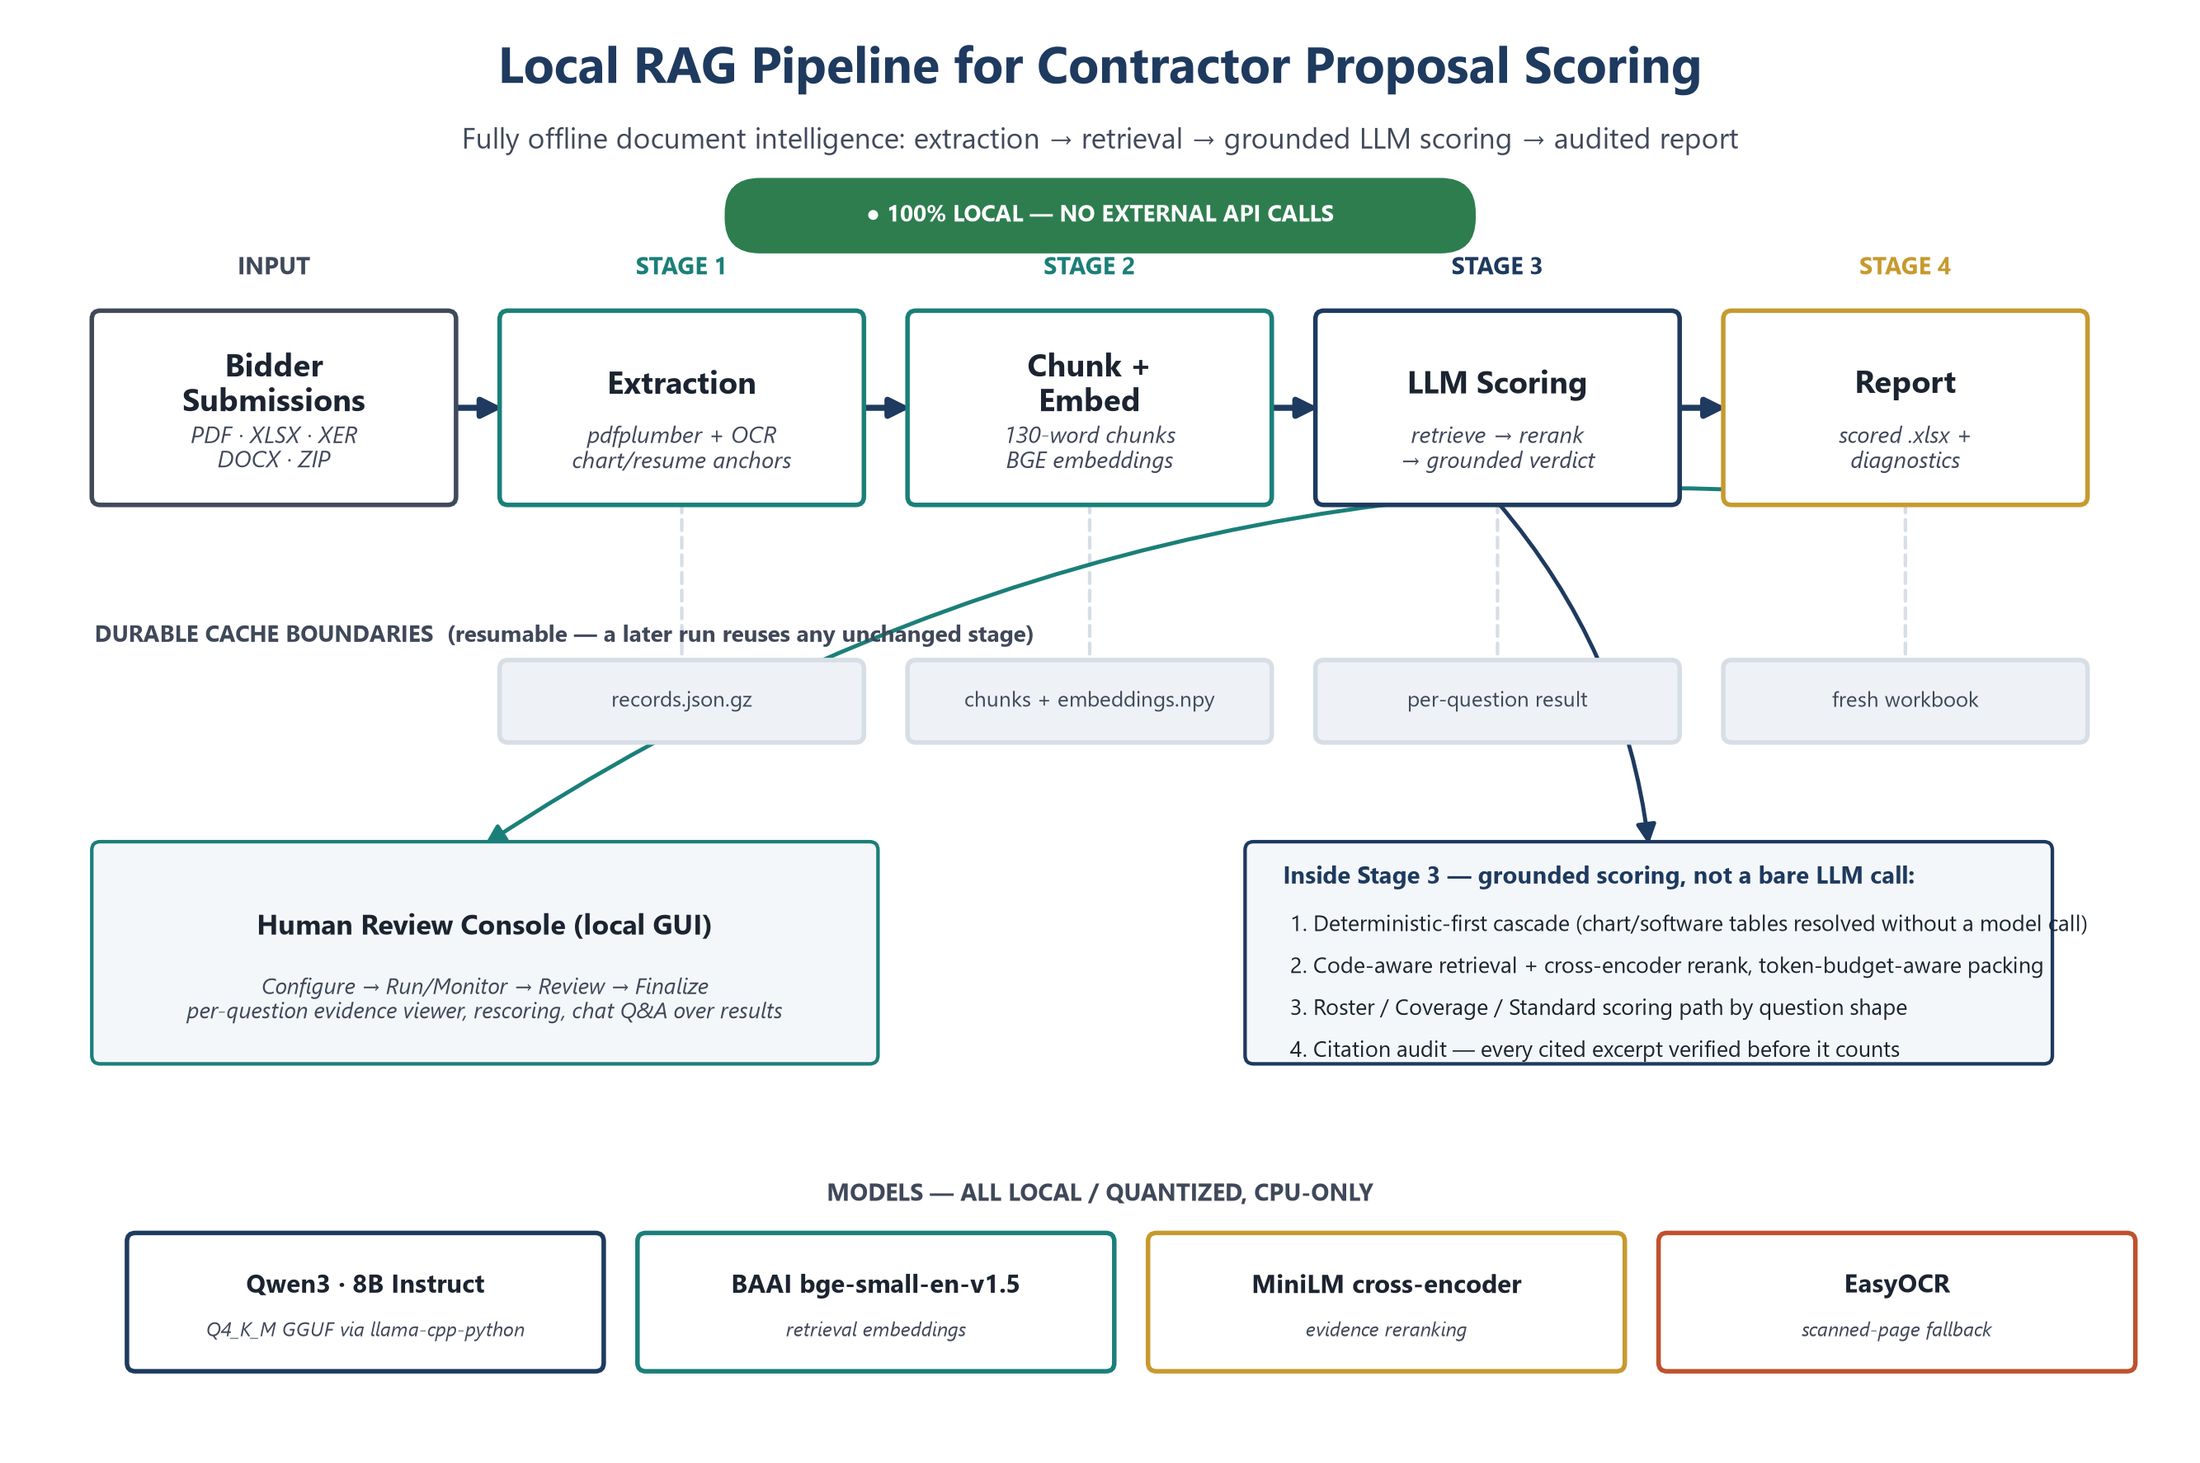
Built an on-device AI proposal-review tool that reduced estimated review effort from 126 hours to 8, with source-linked scores and protected documents kept local.
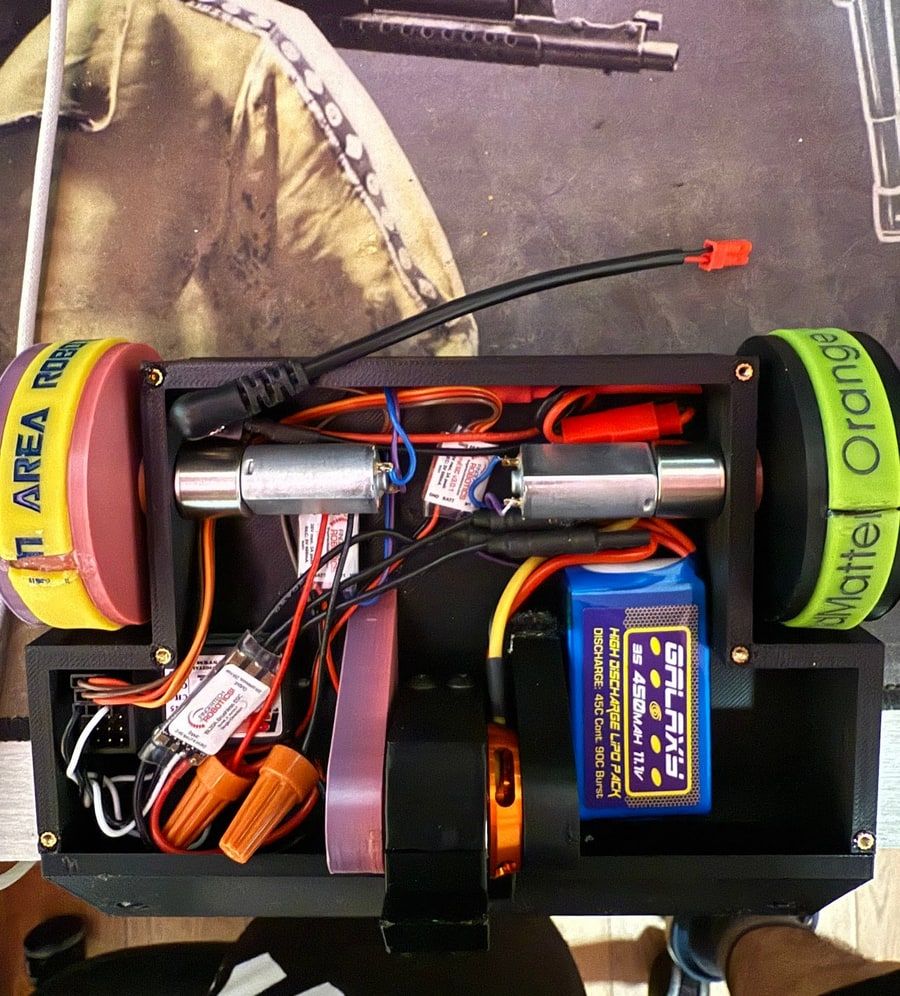
Designed and built a three-pound combat robot with a vertical drum and a modular printed chassis, reducing chassis mass by 30%.
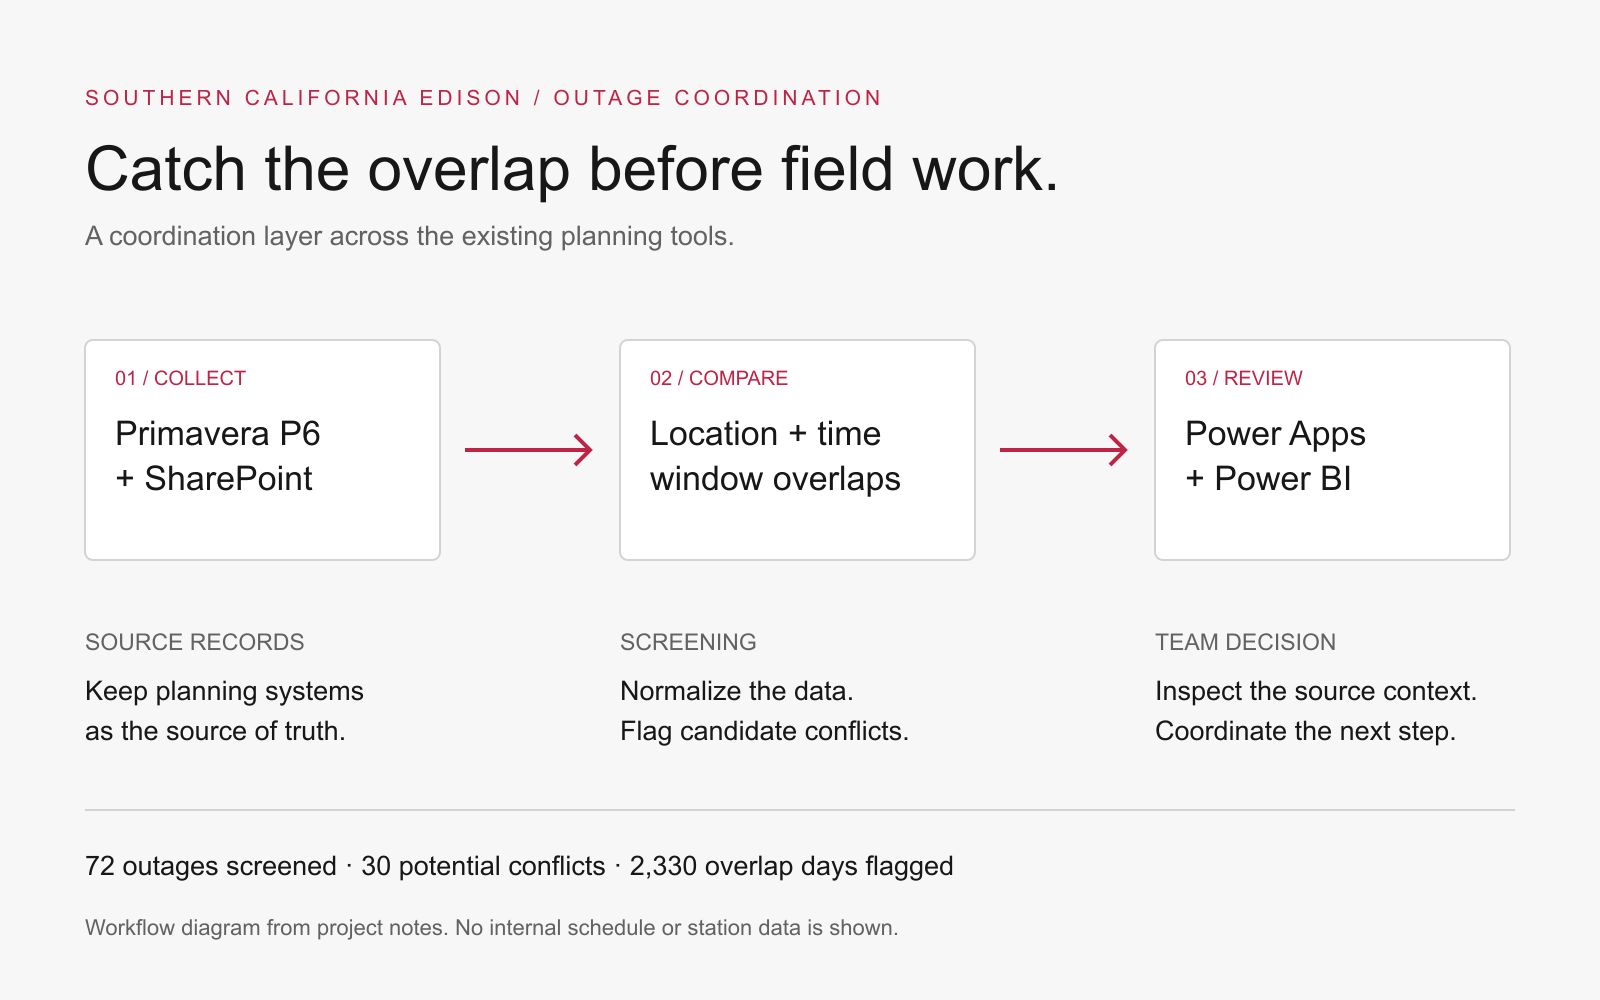
Connected outage planning data in Power Apps and Power BI to screen 72 outages and flag 30 potential schedule conflicts for project teams to review.
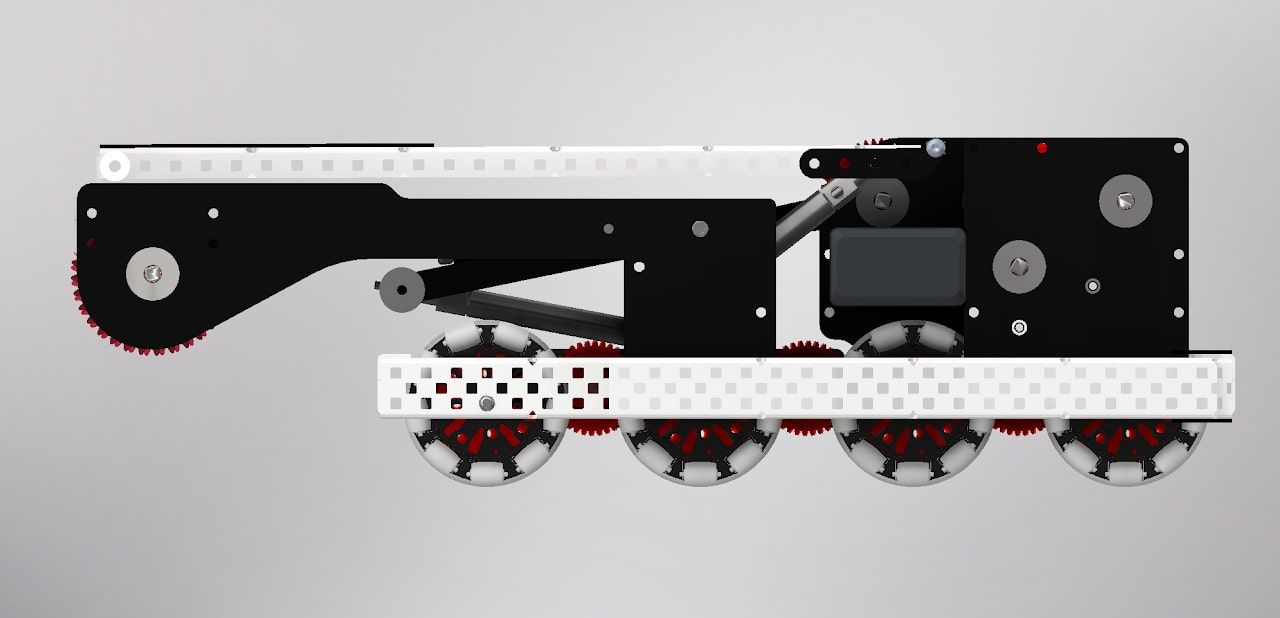
Led the mechanical design of a low-profile VEX robot, fitting the drivetrain, intake, launcher, and roughly 50 components into an 18 × 18 × 6-inch package.
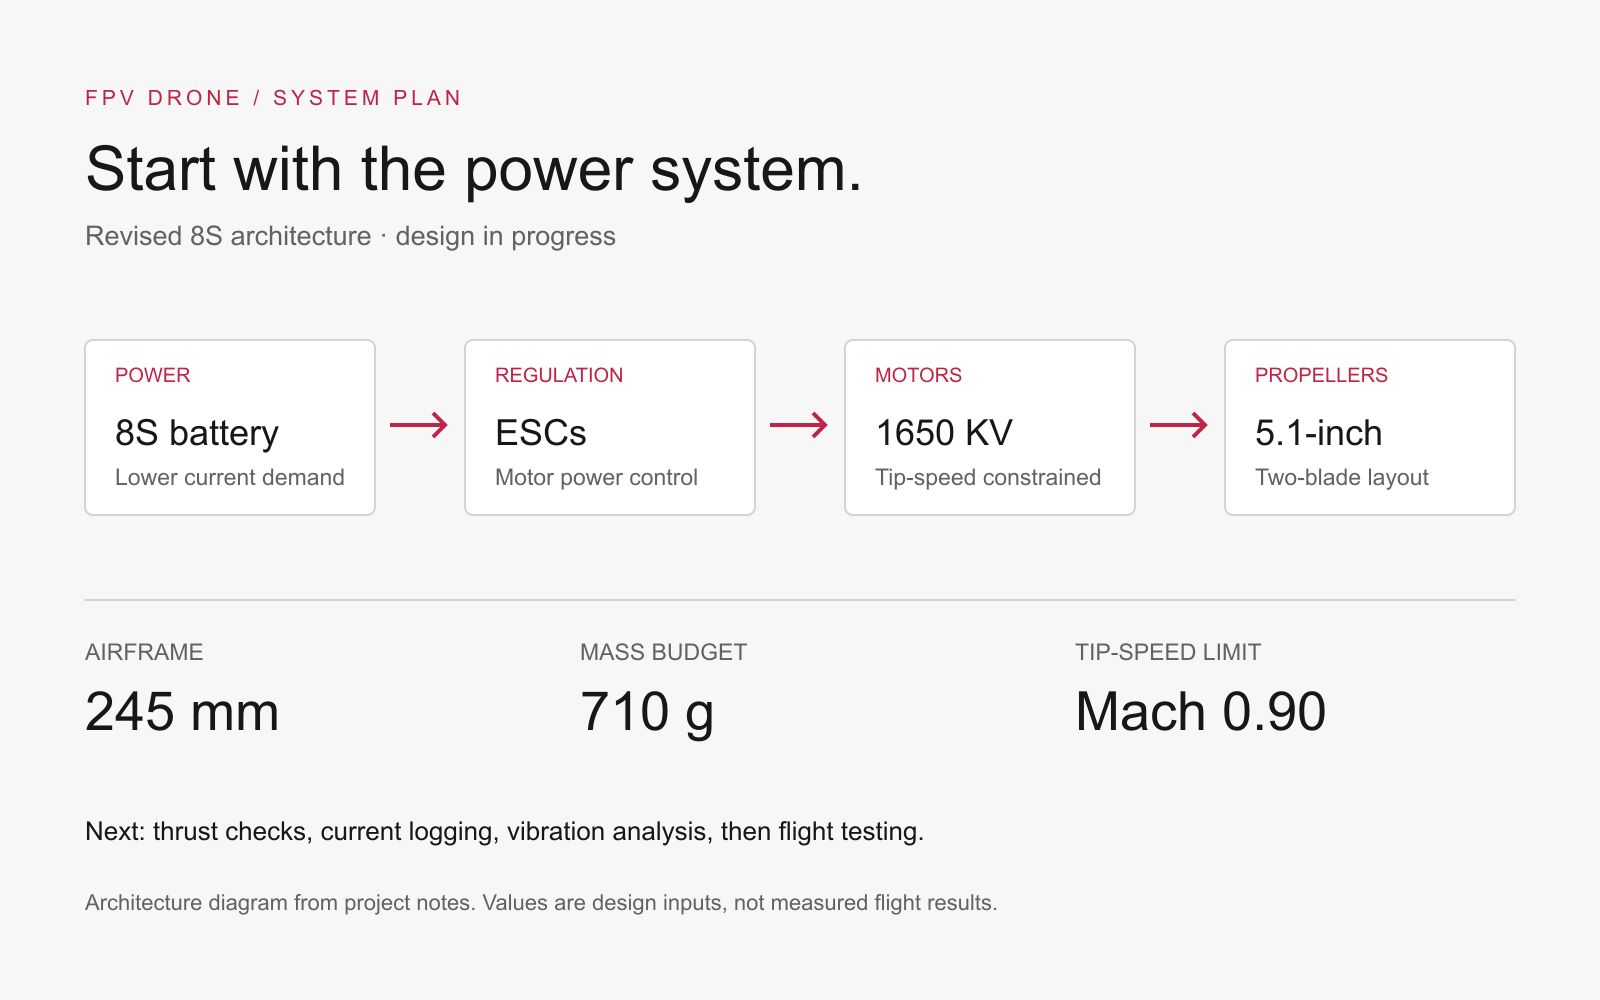
Designing an 8S FPV drone around a 245 mm frame and a 710 g mass budget, balancing propulsion, packaging, and aerodynamic constraints. Build and flight testing are in progress.