Perrybotics 2025: High Stakes
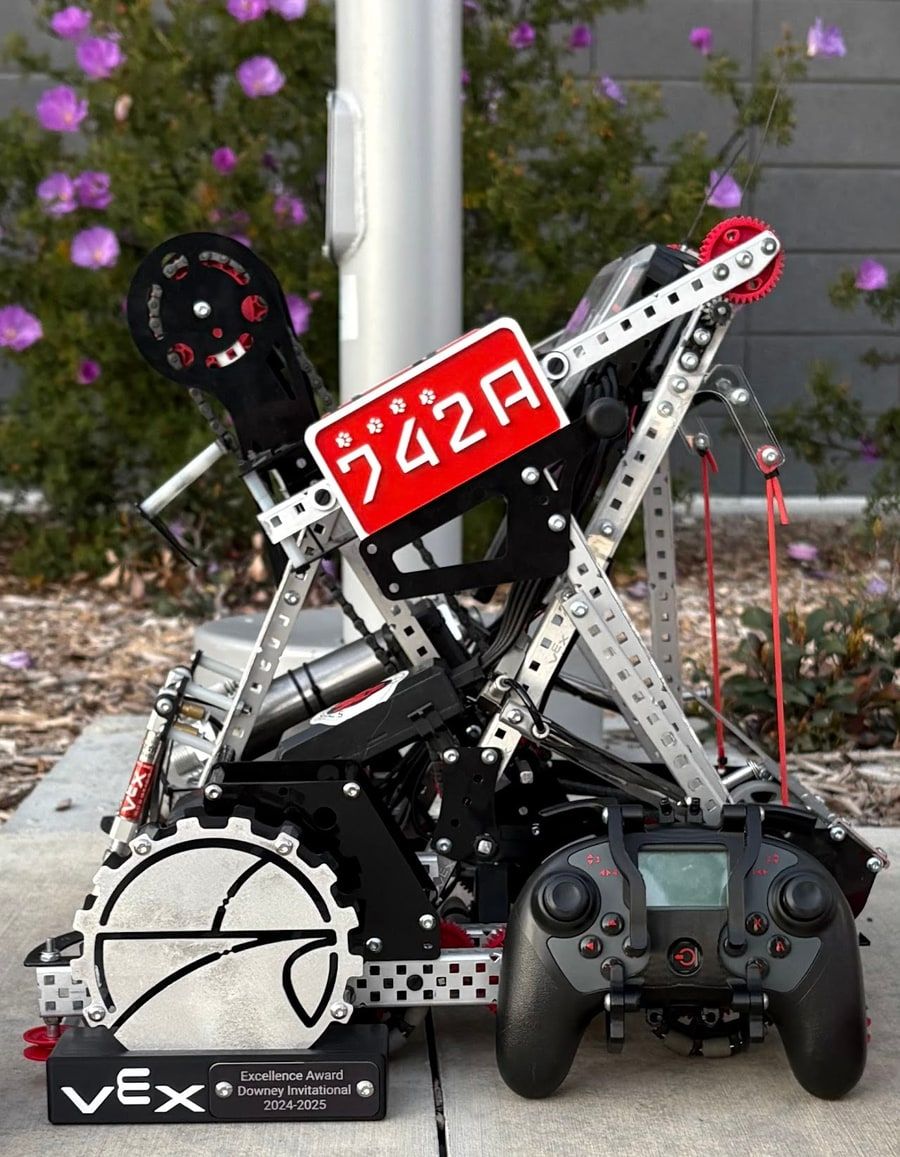
Led mechanical design and fabrication of a compact VEX robot, refining the drivetrain and mechanisms through three major iterations and removing 1.5 lb from the build.
Stanford Mechanical Engineering student pursuing a Computer Science minor · Expected June 2029
Competition robots, a combat robot, and an FPV drone in development. Explore the mechanisms, manufacturing choices, and iterations behind each build.
Seeking mechanical engineering, robotics, software, and applied AI internships and co-ops.
Led mechanical design and fabrication of a compact VEX robot, refining the drivetrain and mechanisms through three major iterations and removing 1.5 lb from the build.
I led the mechanical design, CAD, fabrication, and iteration with the Perrybotics team.
Designed and built a three-pound combat robot with a vertical drum and a modular printed chassis, reducing chassis mass by 30%.
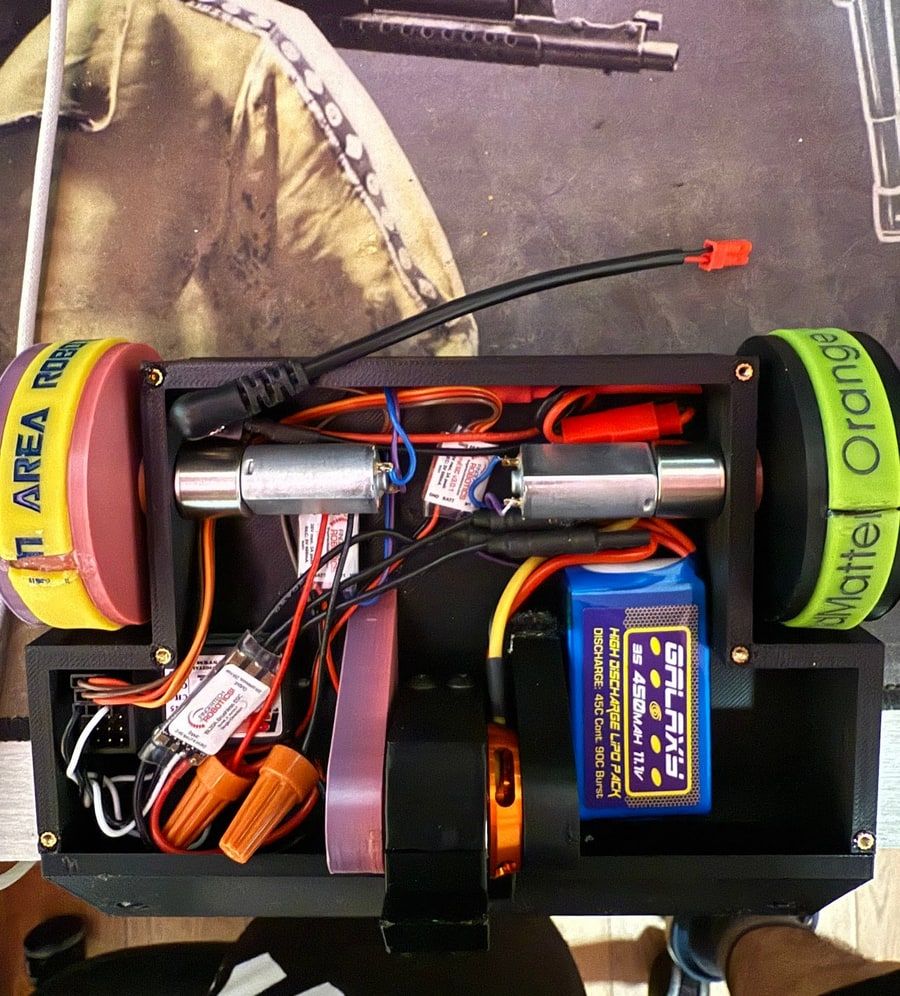
I designed, sourced, fabricated, wired, and assembled this three-pound vertical drum spinner myself.
Led the mechanical design of a low-profile VEX robot, fitting the drivetrain, intake, launcher, and roughly 50 components into an 18 × 18 × 6-inch package.
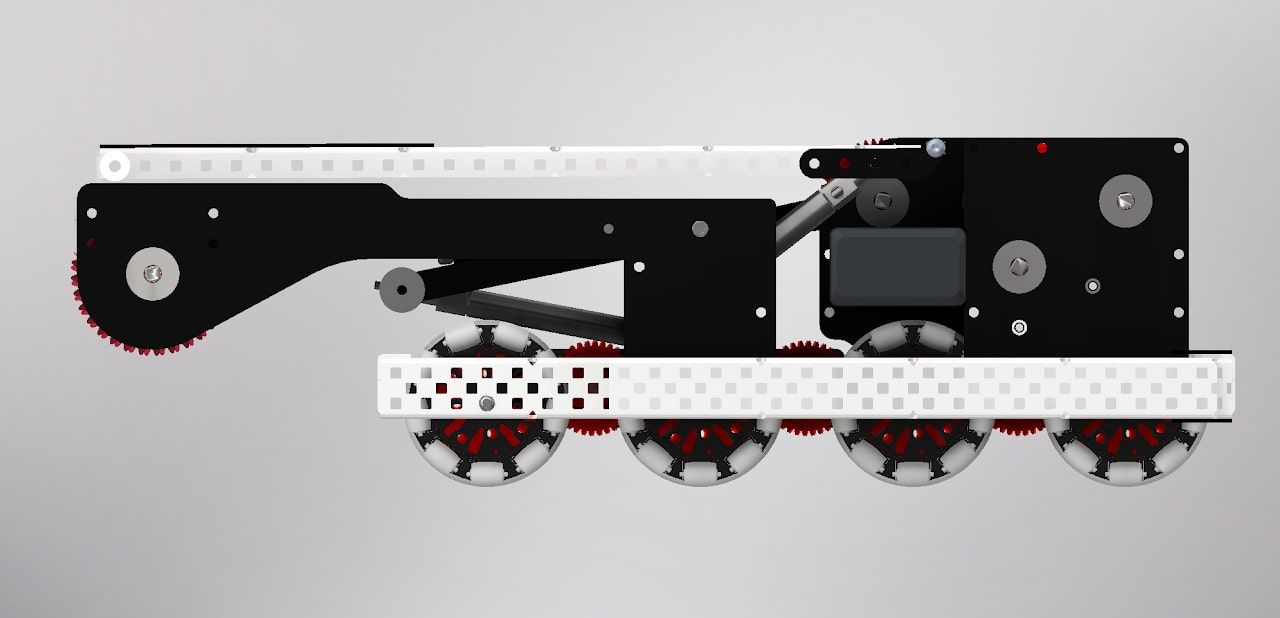
I led the mechanical design and helped build the chassis, intake, and catapult with the Perrybotics team.
Designing an 8S FPV drone around a 245 mm frame and a 710 g mass budget, balancing propulsion, packaging, and aerodynamic constraints. Build and flight testing are in progress.
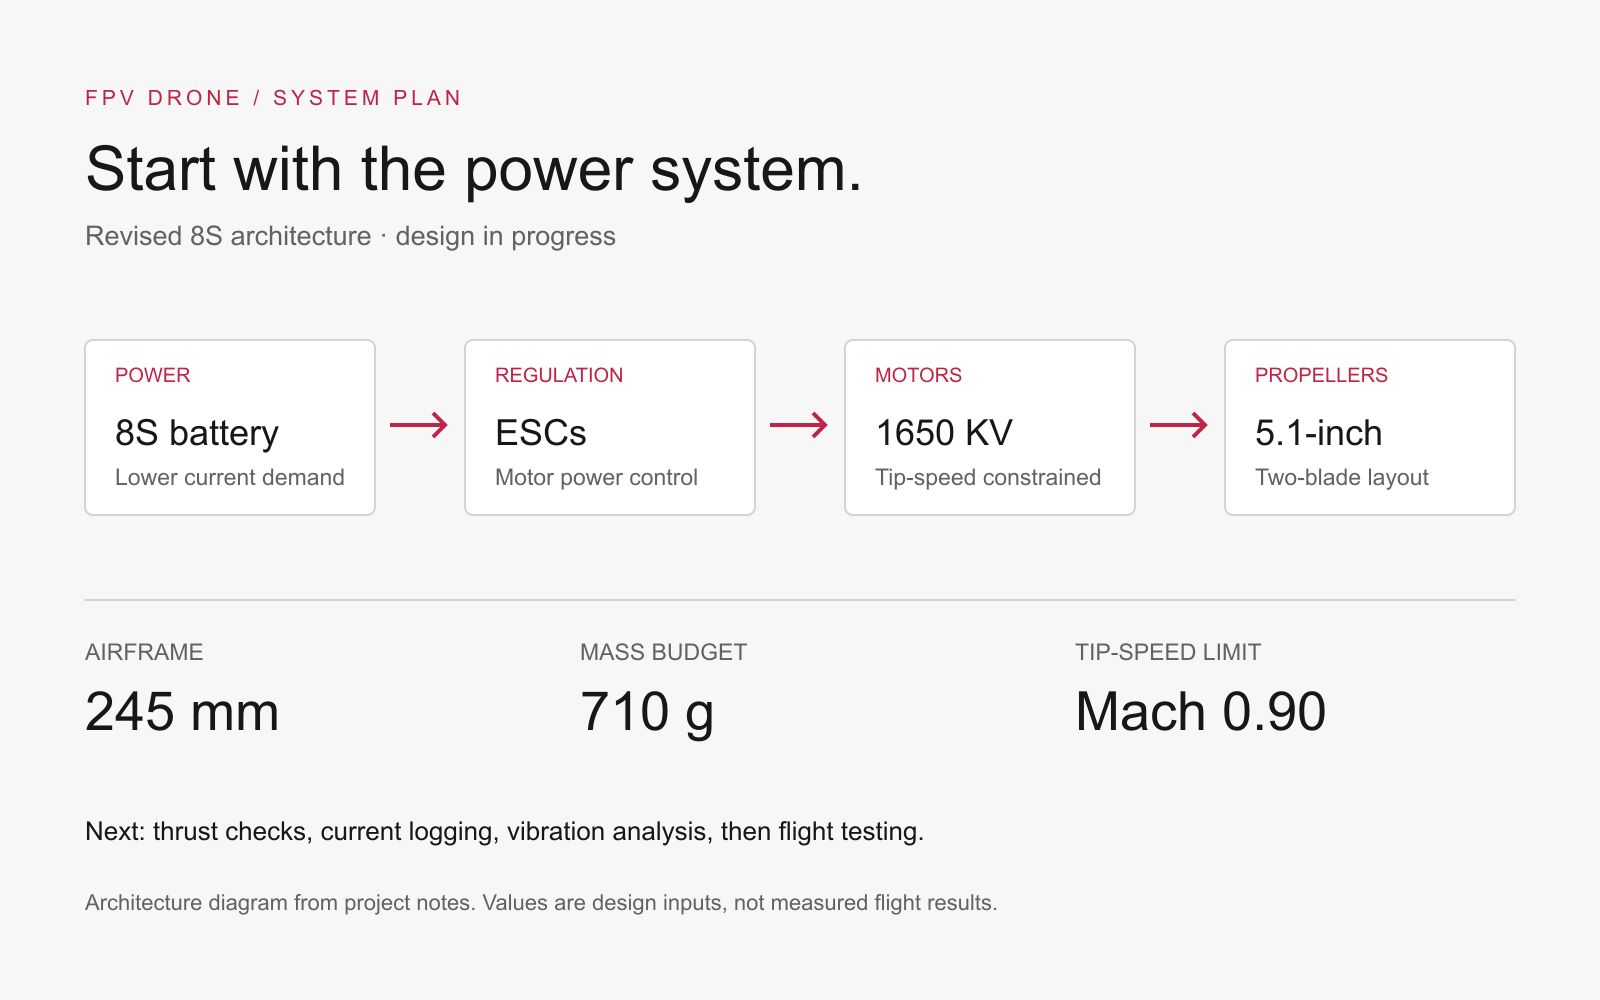
I’m handling the airframe design, propulsion calculations, CAD, component selection, and test plan for this independent drone build.
Explore the other side of the work